CAN FD Receive
R2026bCAN FD Receive block
To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Raspberry Pi Blockset /
Communication
Description
The CAN FD Receive block receives messages from a Controller Area Network Flexible Data Rate (CAN FD) interface and outputs the received data for processing in a Simulink® model. Use this block to read CAN FD frames from a configured CAN interface on Raspberry Pi® hardware. The block supports both raw CAN FD output and structured message output enabling workflows for direct data processing or message-based applications.
The block supports two output workflows:
In the
Raw datamode, the block outputs received message bytes as auint8vector.In the
CAN Msgmode, the block outputs a Simulink bus signal representing a CAN FD message. To extract individual fields from this message, use the CAN FD Unpack (Embedded Coder) block.
The block supports CAN FD message sizes up to 64 bytes and enables reception of CAN FD frames that use higher data rates during the data phase when bit rate switching is enabled.
Note
To generate C/C++ code for this block, you must have an Embedded Coder® license.
The CAN FD Receive block also supports reception of classical CAN messages when the CAN interface is configured for CAN FD. To receive classical CAN messages, do not use bit rate switching and make sure the message size is 8 bytes or less.
For more information on how to enable the SPI interface and configure the MCP2518FD CAN FD controller for CAN FD configuration, see Enable and Configure Raspberry Pi for SPI and CAN FD Communication Using Waveshare 2-CH CAN FD HAT.
Examples
Receive CAN FD message data.
Use this workflow to directly process received CAN FD message data bytes without using structured CAN FD message. This approach is suitable for applications that operate on byte-level data or require minimal overhead.
In the CAN FD Receive block, set Data to be output
as to Raw data to enable direct CAN FD data
reception using a byte vector.
Specify Message length based on the number of bytes to receive. Use a value to match one of the supported CAN FD message sizes.
Configure additional message parameters such as:
Identifier type — Standard or Extended
Run the model to receive the CAN FD frame over the configured CAN interface.
During simulation, the block extracts data bytes from received CAN FD frames and
outputs them as a uint8 vector. Each element in the output
corresponds to one byte of the received message.
Receive CAN FD messages using a message-based workflow.
Use this workflow to receive CAN FD frames as structured message signals. This approach is suitable when you need access to message fields such as identifier, message, and CAN FD-specific signals. In this mode, the CAN FD Receive block outputs a Simulink bus signal that represents a complete CAN FD message. The message structure can be processed using a CAN FD Unpack (Embedded Coder) block which provides a consistent interface for extracting frame attributes.
Add a CAN FD Receive block to your Simulink model.
Set Data to be output
as to CAN Msg to enable the block to output
structured message data.
Connect the output of the CAN FD Receive block to the input port of the CAN FD Unpack (Embedded Coder) block.
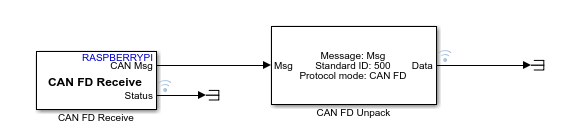
Configure these message fields in the CAN FD Receive block:
Identifier type — Standard or Extended
Run the model to receive CAN FD messages.
During simulation, the CAN FD Receive block constructs a CAN FD message from the received data and outputs it as a structured bus signal. All message fields, including identifier, message, and protocol-specific flags, are derived directly from the received frame. The block preserves these values and outputs the message without modification.
Receive only specific CAN FD messages based on identifier and message size.
Use this workflow to filter incoming CAN FD traffic and process only relevant messages. This approach is useful when multiple nodes transmit data on the same CAN bus.
In the CAN FD Receive block, set Identifier type to match the incoming message format.
Specify Message ID to filter the desired CAN FD frame.
Set Message length to match the expected message size.
Run the model to receive filtered CAN FD messages.
During simulation, the block selects and outputs only those CAN FD frames that match the specified identifier and message length. Messages that do not meet the filter criteria are ignored.
Monitor receive status and detect communication issues.
Use this workflow to track message reception and identify error conditions during CAN FD communication.
In the CAN FD Receive block, select Output error.
Monitor the Error output port.
Run the model to receive CAN FD messages.
During simulation, the block outputs an error value indicating any communication errors during message reception.
Extended Examples
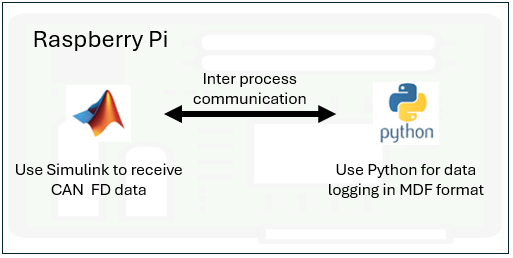
Log CAN Bus Data on Raspberry Pi
Use Raspberry Pi® Blockset to monitor a controller area network (CAN) bus, perform basic CAN conversions, and log CAN FD data in a measurable data format (MDF) file. This example also showcases the interoperability between a model deployed in Simulink® and a Python® program running simultaneously on Raspberry Pi hardware.
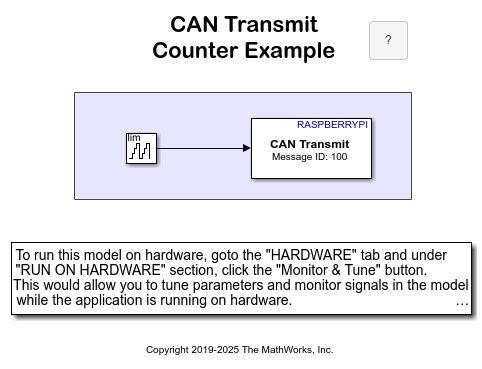
Transmit and Receive Data Using Raspberry Pi CAN Blocks
To use Raspberry Pi® Blockset to transmit and receive data from the CAN network using the specified CAN device.
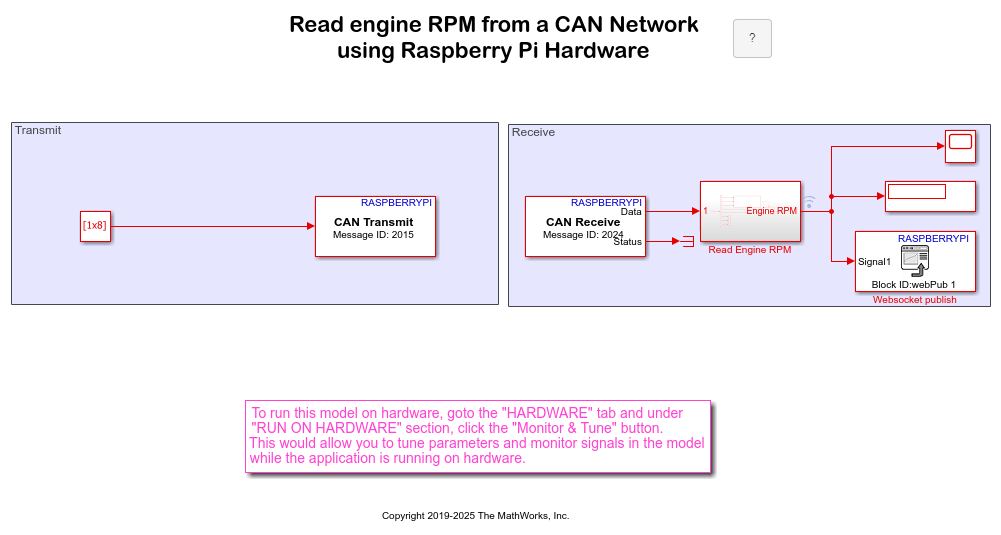
Monitor Engine RPM Using Raspberry Pi CAN Blocks
Use Raspberry Pi® Blockset to monitor vehicle engine RPM and read the data on a web browser.
Ports
Output
Parameters
Extended Capabilities
Version History
Introduced in R2026b

