Collision Sphere
R2026bcollision sphere block block
To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Robotics System Toolbox /
Collision Detection
Description
The Collision Sphere block outputs a sphere collision geometry with the origin of the geometry-fixed frame at the center of the sphere.
Examples
Open the Simulink® model. This model contains all five of the collision geometry blocks in the Collision Detection library and checks for collision between any two of the collision geometries. Note that the Collision Mesh block uses vertices from the exampleMeshVertices MAT file. The model loads the exampleMeshVertices MAT file when you open the model by using the PreLoadFcn callback.
model = "CollisionCheckingBetweenGeometries.slx";
open_system(model)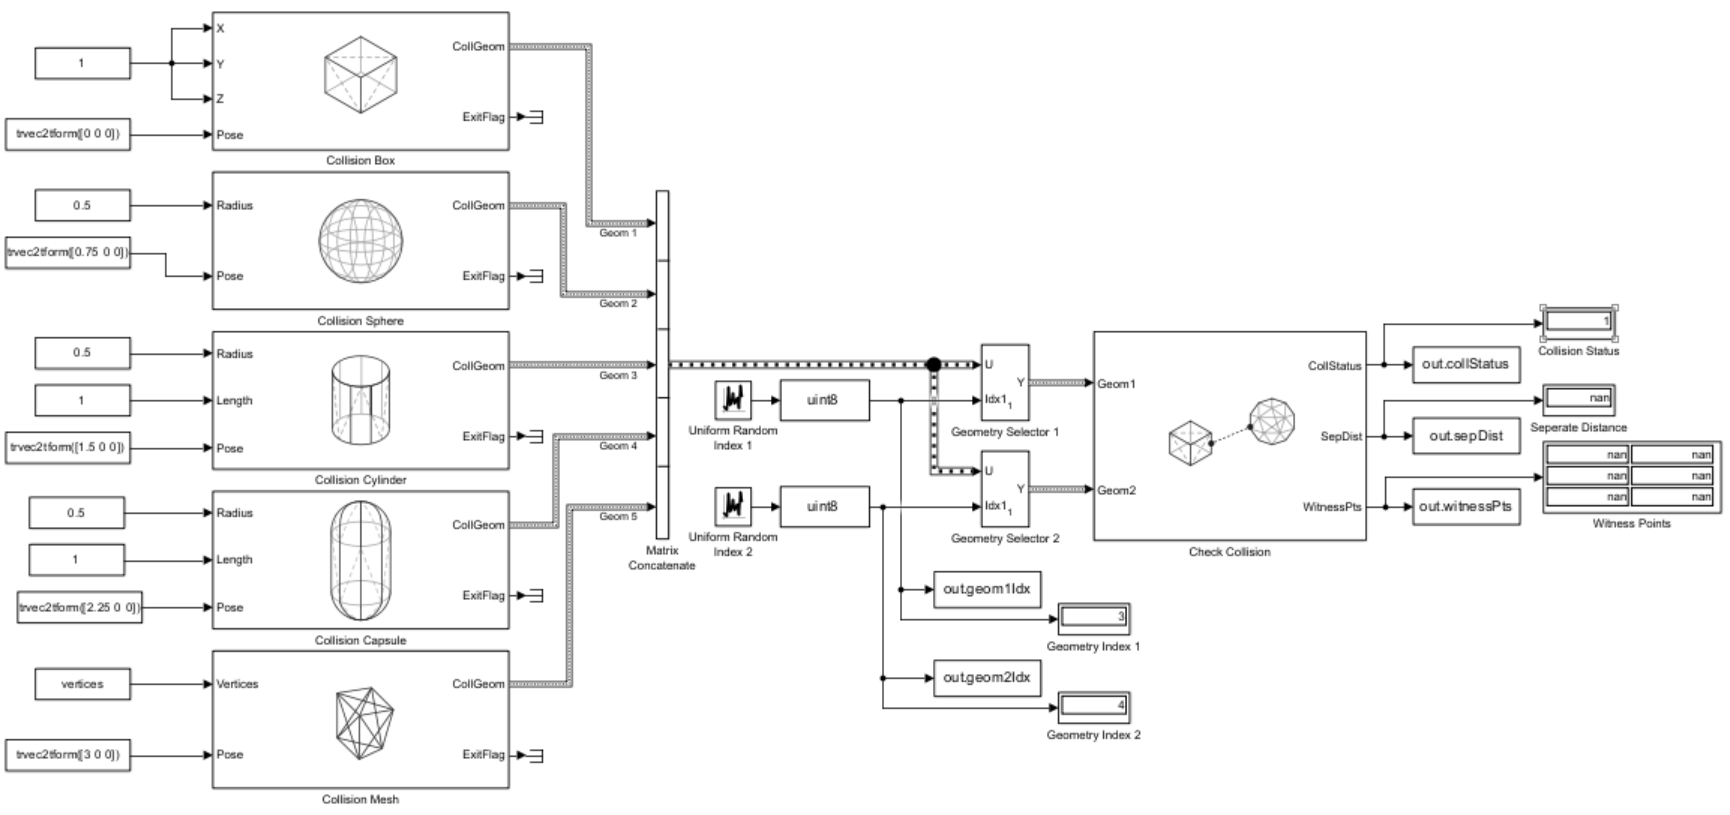
Simulate the model.
out = sim("CollisionCheckingBetweenGeometries.slx")out =
Simulink.SimulationOutput:
collStatus: [1x1 timeseries]
geom1Idx: [1x1 timeseries]
geom2Idx: [1x1 timeseries]
logsout: [1x1 Simulink.SimulationData.Dataset]
sepDist: [1x1 timeseries]
tout: [101x1 double]
witnessPts: [1x1 timeseries]
SimulationMetadata: [1x1 Simulink.SimulationMetadata]
ErrorMessage: [0x0 char]
Get data from the simulation output.
collCheckingPairs = [out.geom1Idx.Data out.geom2Idx.Data];
collStatuses = out.collStatus.Data;
sepDistances = out.sepDist.Data;
witnessPoints = out.witnessPts.Data;
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"robotslcollision/Collision Sphere"
Example: add_block("robotslcollision/Collision Sphere","myModel/myBlock",MakeNameUnique="on")
More About
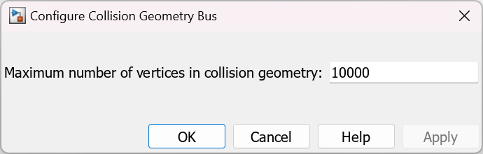
To configure the maximum number of vertices in a collision geometry block, click
Configure Collision Geometry Bus in the block mask to open the
Configure Collision Geometry Bus dialog box, and set the Maximum number of
vertices in collision geometry parameter. The default number of vertices is
10000.
Extended Capabilities
Version History
Introduced in R2025a

