Vector Field Histogram
R2026bAvoid obstacles using vector field histogram
Vector Field Histogram block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Navigation Toolbox /
Control Algorithms
Description
The Vector Field Histogram (VFH) block enables your vehicle to avoid obstacles based on range sensor data. Given a range sensor reading in terms of ranges and angles, and a target direction to drive toward, the VFH controller computes an obstacle-free steering direction.
For more information on the algorithm details, see Vector Field Histogram under Algorithms.
Examples
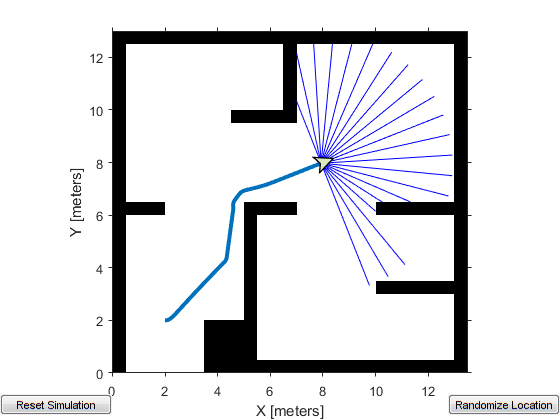
Path Following with Obstacle Avoidance in Simulink
Use Simulink® to avoid obstacles while following a path for a differential drive robot. This example uses ROS to send and receive information from a MATLAB-based simulator. You can replace the simulator with other ROS-based simulators such as Gazebo®.
Limitations
The
RangesandAnglesinputs are limited to 4000 elements when generating code for models that use this block.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"navlib/Control Algorithms/Vector Field Histogram"
Example: add_block("navlib/Control Algorithms/Vector Field Histogram","myModel/myBlock",MakeNameUnique="on")
Algorithms
Extended Capabilities
Version History
Introduced in R2019b
See Also
Blocks
- Pure Pursuit | Publish (ROS Toolbox) | Subscribe (ROS Toolbox) | Timed Elastic Band

