Ultra-Local Model
R2026bEstimate nonlinear plant as single or double integrator systems with an affine term that captures unknown dynamics and disturbances
Since R2025a
Ultra-Local Model block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Simulink Control Design /
Disturbance Observer
Description
Ultra-local model (ULM) is an estimation technique that allows you to approximate a nonlinear plant as a single or double integrator system with an affine term that captures unknown dynamics and disturbances. The estimated model is valid only for a local operating point over a short period of time. You can the Ultra-Local Model block for ULM-based estimation. Using this block, you can estimate first-order and second-order local plant dynamics of the following form:
First order —
Second-order —
Here, α is the input gain for tuning and F is the affine term for combined uncertain dynamics and external disturbances.
You can use this block either as a standalone estimator for disturbance estimation and output prediction or use its disturbance estimation capabilities for improving nominal controller performance.
For more information about ULM-based estimation, see Ultra-Local Model for Disturbance Estimation and Compensation.
Examples
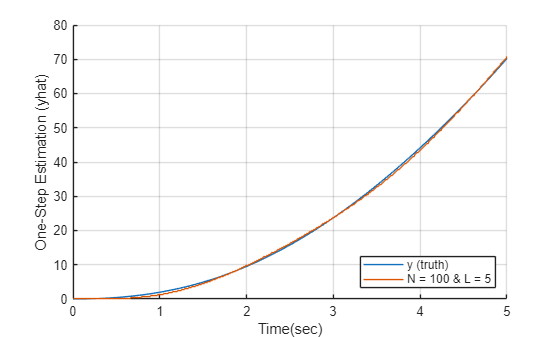
Ultra-Local Model for System Identification and Output Prediction
Use the Ultra-Local Model block for system identification and output prediction.
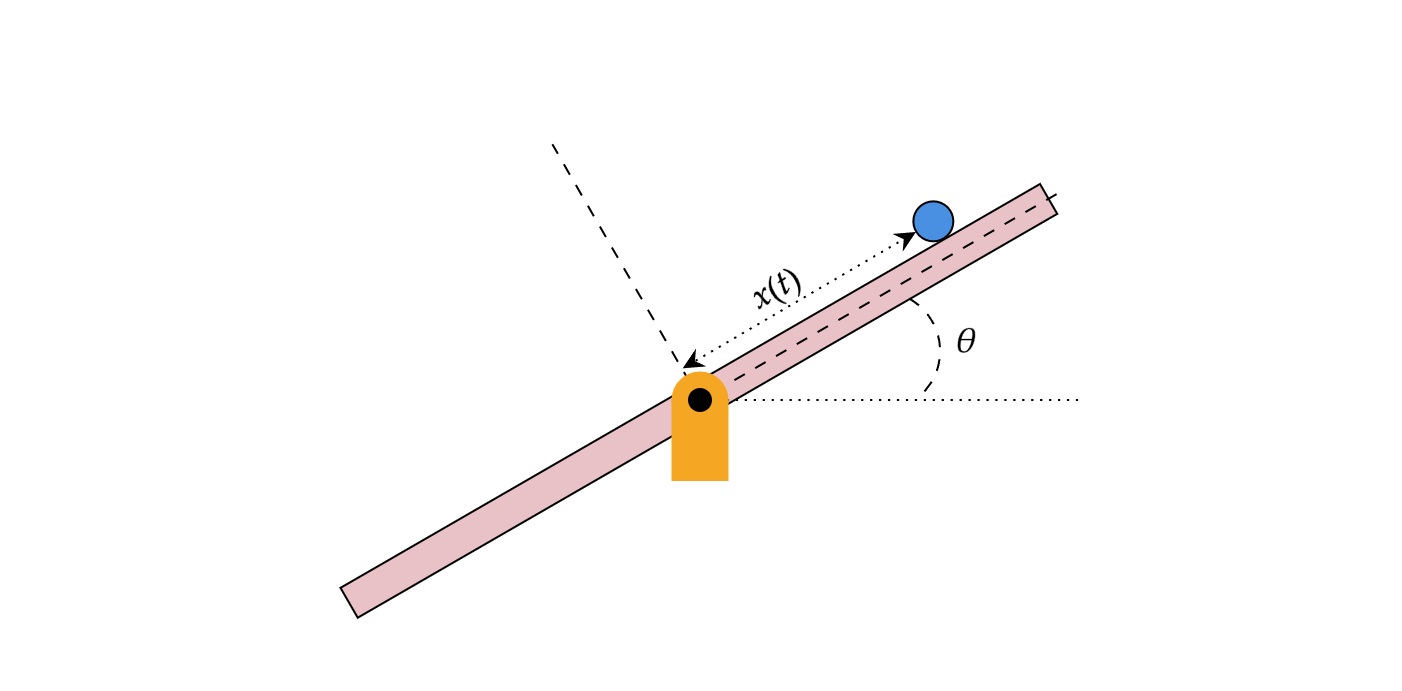
Intelligent PID Using Ultra Local Model for Ball on Beam Balance
Implement model-free intelligent PID control technique using ultra-local model.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"slctrl_disturbance/Ultra-Local Model"
Example: add_block("slctrl_disturbance/Ultra-Local Model","myModel/myBlock",MakeNameUnique="on")
For information about programmatic access to individual block parameters, see the Programmatic Use section of parameter descriptions on this page.
Extended Capabilities
Version History
Introduced in R2025a

