Hall Speed and Position
R2026bCompute speed and estimate position of rotor by using Hall sensors
Hall Speed and Position block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Motor Control Blockset /
Control /
Synchronous Machine /
Position Decoders /
Sensor Decoders
Description
The Hall Speed and Position block computes the mechanical speed of the rotor by tracking changes in the Hall state. The block also estimates the electric position of the rotor by using the direction, Hall state, and external counter value inputs.
The block executes periodically after a fixed time interval that the controller algorithm defines.
Examples
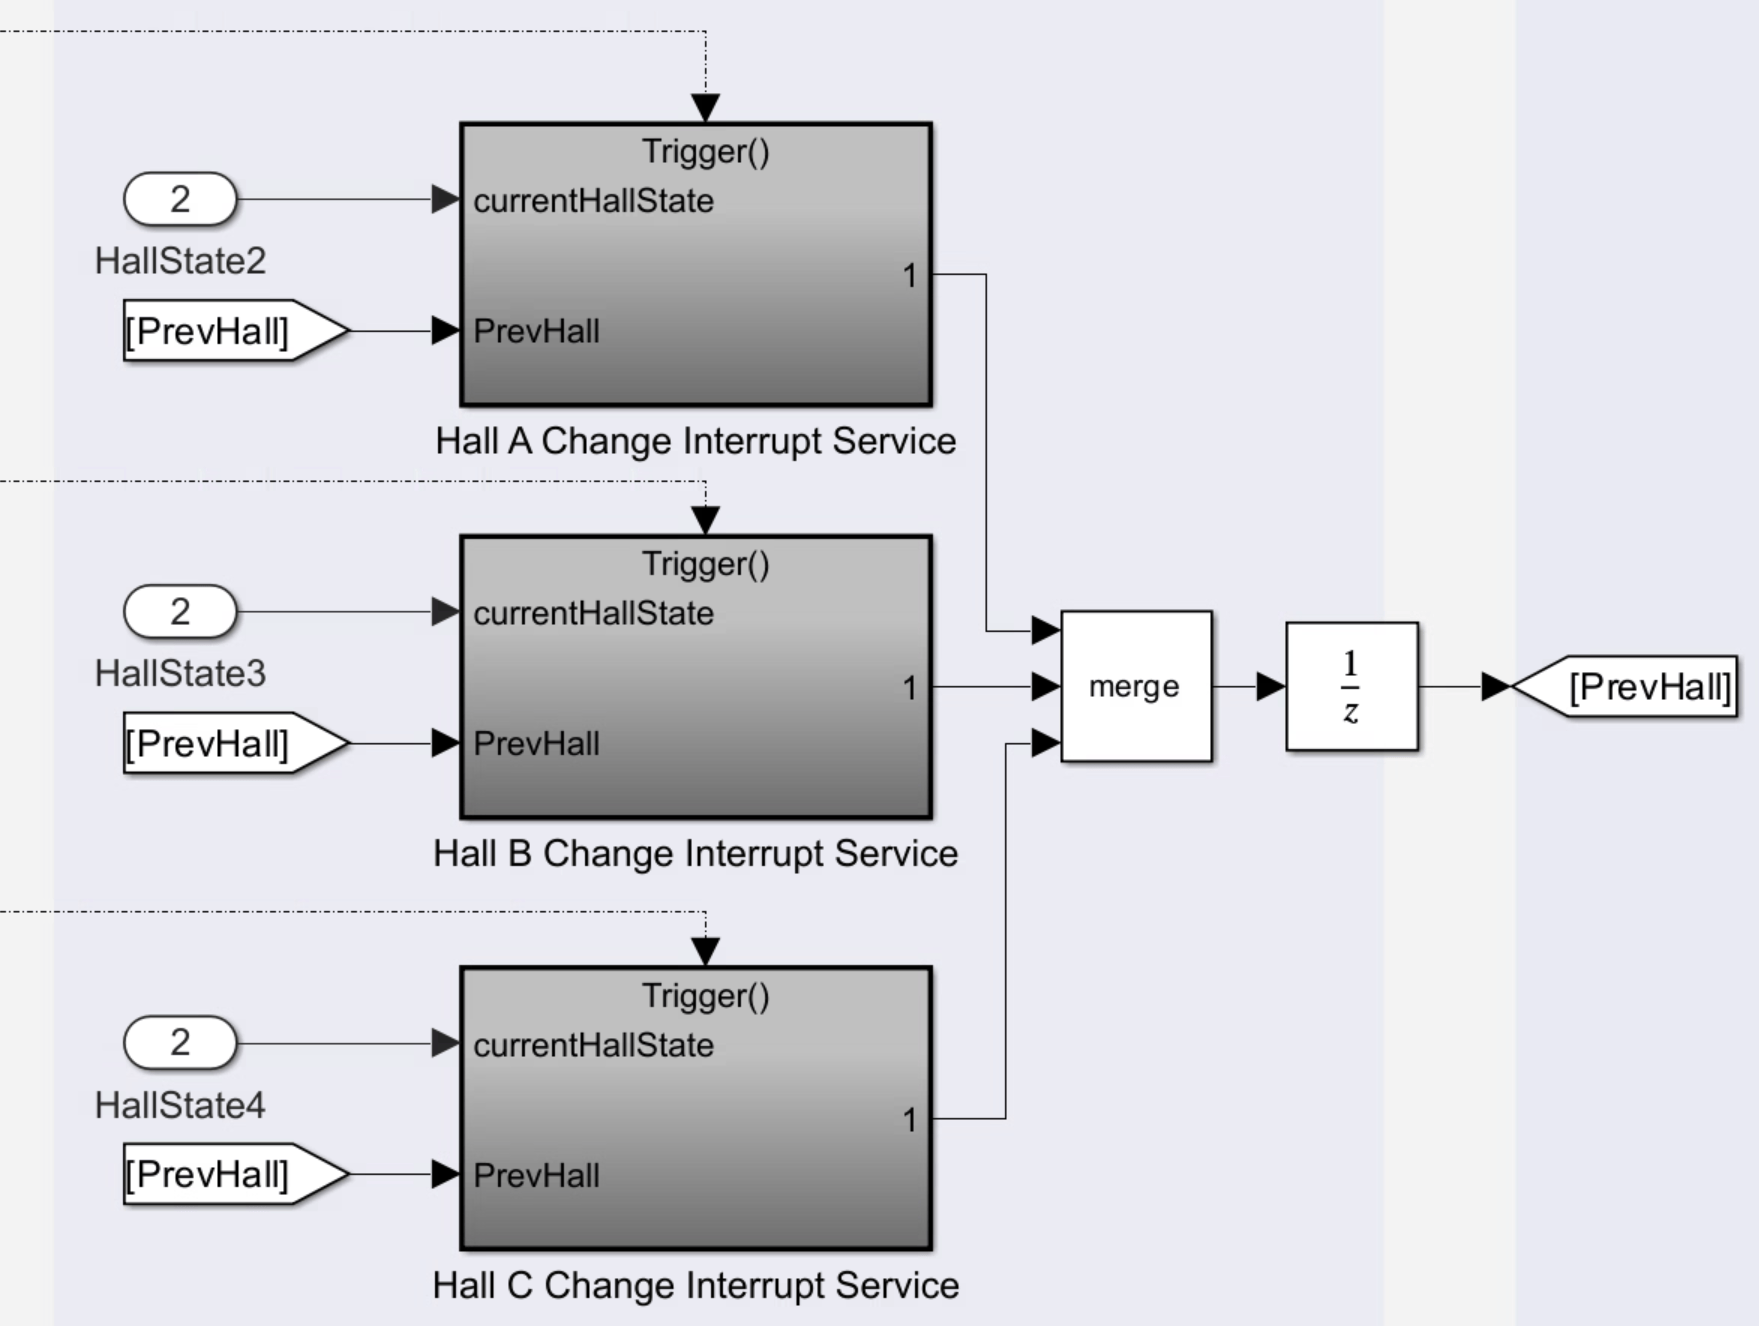
How to Use Hall Validity and Hall Speed and Position Blocks
Integrate Hall Validity and Hall Decoder blocks with field-oriented control (FOC) algorithm.
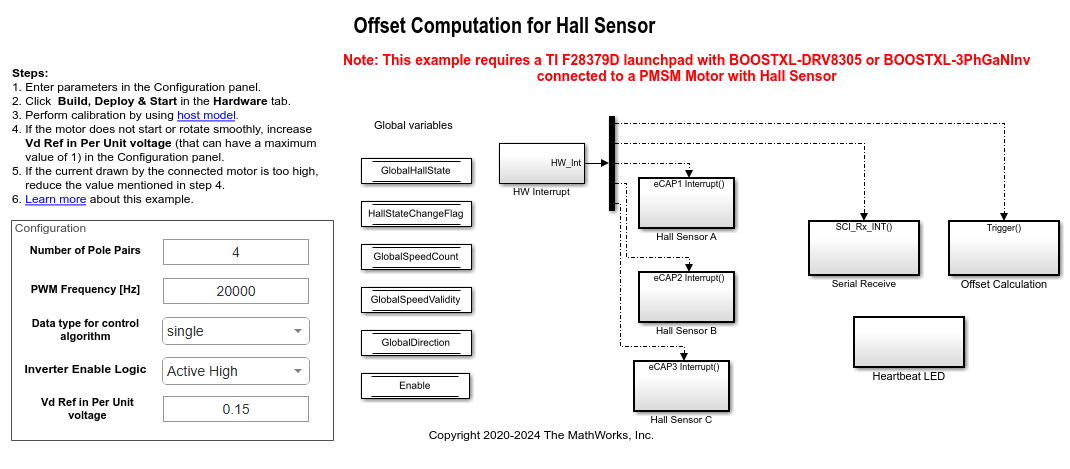
Hall Offset Calibration for PMSM
Calculates the offset between the rotor direct axis (d-axis) and position detected by the Hall sensor. The field-oriented control (FOC) algorithm needs this position offset to run the permanent magnet synchronous motor (PMSM) correctly. To compute the offset, the target model runs the motor in the open-loop condition. The model uses a constant Vd (voltage along the stator's d-axis) and a zero Vq (voltage along the stator's q-axis) to run the motor (at a low constant speed) by using a position or ramp generator. When the position or ramp value reaches zero, the corresponding rotor position is the offset value for the Hall sensors.
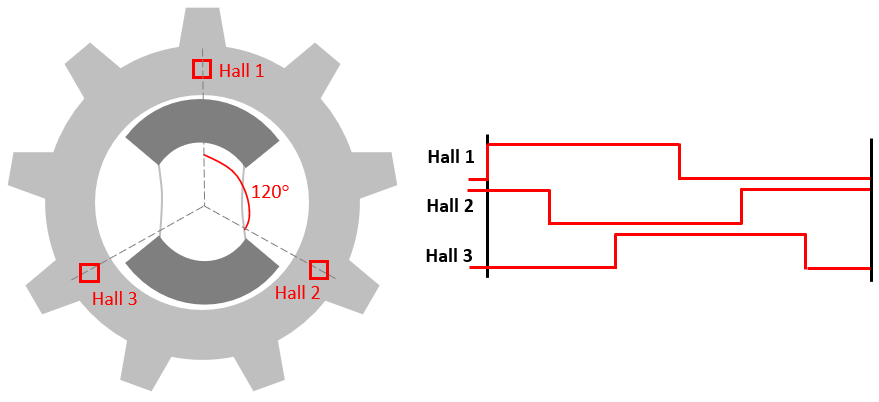
Field-Oriented Control of PMSM Using Hall Sensor
Implements the field-oriented control (FOC) technique to control the speed of a three-phase permanent magnet synchronous motor (PMSM). The FOC algorithm requires rotor position feedback, which is obtained by a Hall sensor. For details about FOC, see Field-Oriented Control.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"mcblib/Control/Synchronous Machine/Position Decoders/Sensor Decoders/Hall Speed and Position"
Example: add_block("mcblib/Control/Synchronous Machine/Position Decoders/Sensor Decoders/Hall Speed and Position","myModel/myBlock",MakeNameUnique="on")
Extended Capabilities
Version History
Introduced in R2020a

